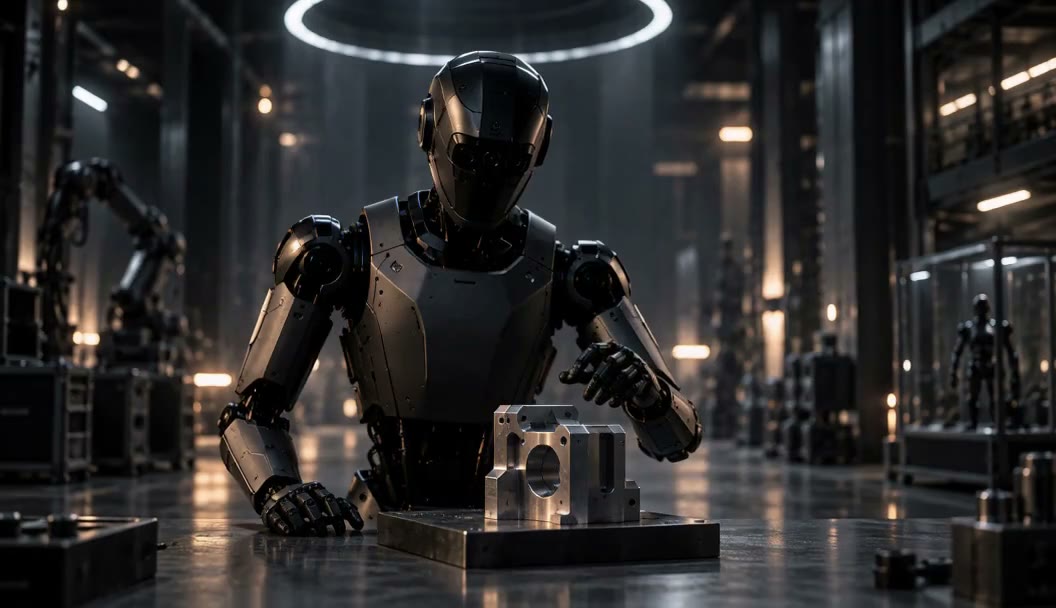
A humanoid robot standing in a dark robotics facility beneath a ring of light.
01AWAKEN

REPLACER

Physical intelligencefor robots.

See. Reason. Act. Adapt.

A humanoid robot inspecting a machined component on a workbench.
02UNDERSTAND

The world doesn’t comewith instructions.

Robots need to understand what they’re looking at — and decide what to do next.
A humanoid robot handling a metal component on a reflective workbench.
03ACT / LEARN

Action creates evidence.

Experience becomes intelligence.

A humanoid robot reaching toward an industrial control panel in a large facility.
04ADAPT
Learn from experience.Face something new.Don’t start from zero.
A humanoid robot standing at dawn before an industrial hangar.
05THE BIG IDEA

Physical intelligencethat compounds.

A robot that can encounter something new — and figure out what to do next.

How we’re building it

We’re building it now.

Measured development across reasoning, perception, interaction, experience and physics simulation.

  • A

    Physical reasoning

    Deciding what to do when the situation was never in the plan.

  • B

    Egocentric perception

    Grounding decisions in observable physical reality.

  • C

    Interaction reasoning

    Learning from contact, motion, success and failure.

  • D

    Experience-linked intelligence

    Turning what happened before into something useful next time.

  • E

    Simulation-first validation

    Test repeatedly. Measure honestly. Move to hardware when it earns it.

Physical intelligence that compounds.

Build intelligence
for the physical world.